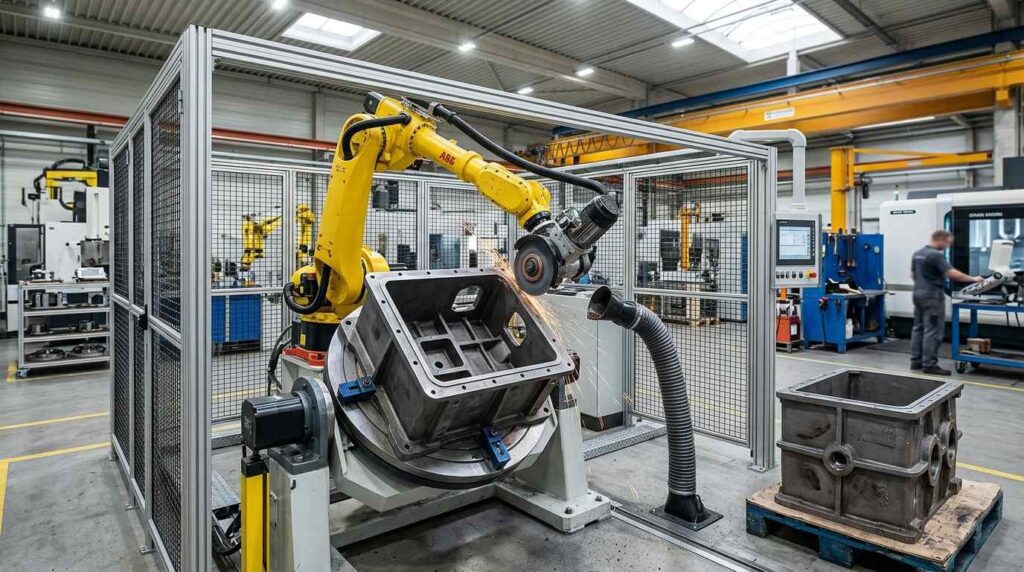
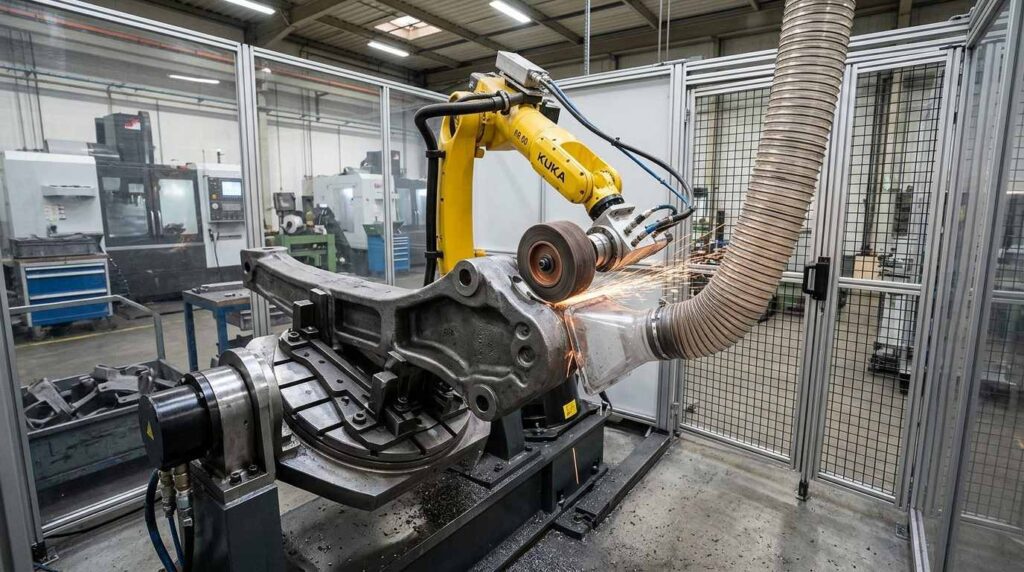
懸臂梁是用於汽車底盤系統、懸吊相關組件、商用車、工程車輛及其他承載型車輛結構的鑄造結構部件。 作為中型鑄鐵或鑄鋼工件,懸臂梁通常包含彎曲的外輪廓、凸起的安裝凸台、孔區、加強肋以及局部過渡區,這些部位均需要穩定的鑄後精加工。.
During casting and rough machining, cantilever beams may develop casting flash, parting lines, burrs and sharp edges around the outer profile, mounting pads, bosses, hole edges and rib transitions. Manual grinding of these local features is repetitive and inconsistent, while robotic grinding provides a more stable method for contour finishing, boss deburring, hole edge treatment and surface preparation before coating or assembly.
What is a Cantilever Beam?
A cantilever beam is a structural support component designed to carry load from one side or support connected parts within a mechanical assembly. In automotive and vehicle applications, this type of cast beam may be used in chassis support areas, suspension-related structures, mounting assemblies or other load-bearing connection positions.
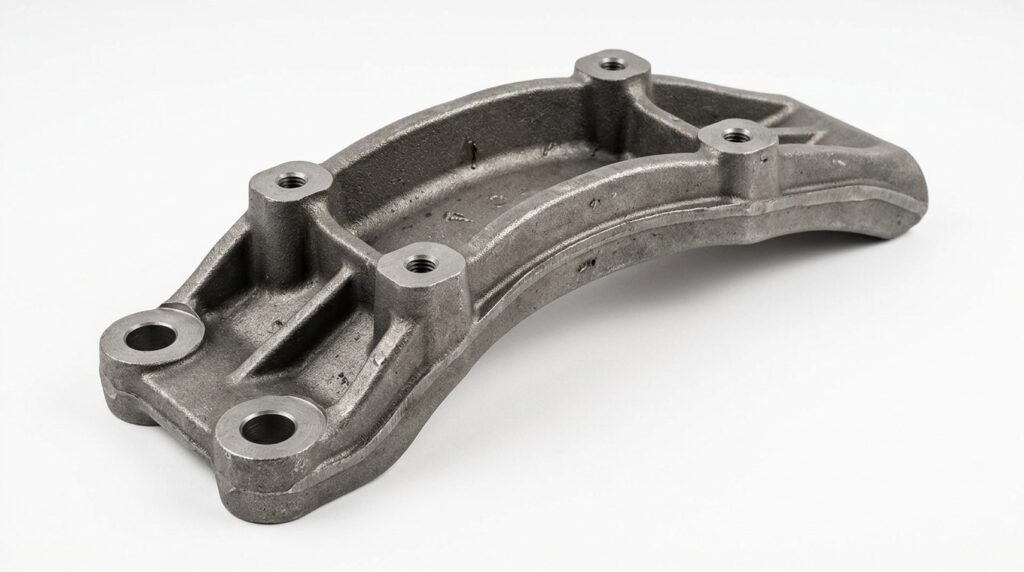
A workpiece of this type has a compact cast structure with curved edges, raised mounting pads, circular boss areas and reinforced transitions. These features improve strength and rigidity, but they also create burr-prone zones after casting. Common finishing areas include outer contours, parting lines, boss edges, mounting pad transitions, rib edges and hole edges.
| 項目 | 詳細資訊 |
|---|---|
| 工件名稱 | Cantilever Beam |
| 典型尺寸 | 730 × 540 × 220 mm |
| 材質 | Cast Iron / Cast Steel |
| 主要製程 | 機器人研磨 |
| 輔助流程 | 去毛刺、圓邊、表面精加工 |
| 主要加工區 | Outer contours, mounting bosses, hole edges, ribs, parting lines |
| 產業 | 汽車與電動車 |
| 完成目標 | Remove casting flash, burrs, sharp edges and local surface defects |
On a structural casting like this, finish quality means clean defects, safe edges and untouched mounting areas — a coating-ready part, not a shiny one.
Typical Applications of Cantilever Beams
Cantilever beams are functional cast structural parts used where strength, positioning stability and load support are required. Their exact shape may vary depending on the vehicle platform, but the finishing requirements are usually focused on burr removal, contour cleaning and edge safety.
| 應用領域 | 典型用途 |
|---|---|
| Automotive Chassis Systems | Cast support beam or structural connection component |
| Suspension Assemblies | Support or connection part near suspension structures |
| 商用車輛 | Medium-sized cast structural support component |
| Engineering Vehicles | Load-bearing cast bracket or beam component |
| Off-Road Vehicles | Reinforced cast support part for chassis-related systems |
| Automotive Casting Production | Batch finishing of cast structural parts |
In these applications, burrs, sharp edges and casting flash may affect coating quality, assembly consistency, fixture positioning and handling safety. A stable robotic grinding process helps manufacturers improve finishing repeatability across batch production.
Pain Point Analysis of Cantilever Beam Finishing
Cantilever beam finishing is challenging because the part combines curved contours, raised bosses, mounting holes, ribs and reinforced transition areas. Burrs and casting flash may remain around the outer profile, raised pads and local rib structures. These areas require different tool angles, making manual grinding unstable and operator-dependent.
Another challenge is mounting-area protection. Some boss surfaces or hole-related areas may be used for positioning, fastening or assembly, so the process must remove burrs and flash without damaging important surfaces. Compared with manual processing, robotic grinding can define clear target zones and repeat the same finishing path for every part.
| 常見問題 | 特定區域 | 影響 |
|---|---|---|
| 鑄造閃光 | Outer contour and parting line areas | Affects coating and appearance consistency |
| Burrs Around Bosses | Raised mounting pads and circular boss areas | May affect assembly and handling safety |
| 尖銳邊緣 | Curved edges, ribs and local transitions | Creates safety and coating risks |
| Hole Edge Burrs | Mounting holes and local openings | May affect installation or fastener assembly |
| 手動變化 | Complex contour and local feature areas | 導致成品品質不穩定 |
| 鑄鐵灰塵 | 研磨作業 | Affects workshop cleanliness and operator comfort |
Compared with manual grinding, robotic grinding provides a more repeatable way to process curved contours, boss edges and hole edges. The robot can follow defined tool paths, maintain stable tool movement and reduce variation caused by operator fatigue or inconsistent hand grinding.
| 比較項目 | 手動研磨 | 機器人研磨 |
|---|---|---|
| Contour Finishing | Depends on operator angle and force | Repeatable path and stable tool movement |
| Boss Edge Deburring | Easy to miss local burrs | Dedicated tool path for boss areas |
| Hole Edge Processing | Quality varies between workers | Controlled deburring around defined holes |
| 表面保護 | Hard to control manually | Defined target and protected zones |
| 批量生產 | Difficult to keep consistent | 程式可儲存與重複使用 |
| 塵埃曝露 | Operators work near grinding dust | Can be integrated with dust extraction |
For manufacturers producing automotive cast cantilever beams, robotic grinding helps reduce manual variation and improve consistency on repeated structural parts.
Robotic Grinding Process for Cantilever Beams
A robotic grinding cell for cantilever beams can be configured according to the casting structure, burr locations, production volume and finishing requirements. The system usually includes a six-axis industrial robot, dedicated fixture, abrasive grinding tool, flexible deburring tool, small grinding head, dust extraction system and safety enclosure. For how these elements come together in general, read our robotic grinding guide.
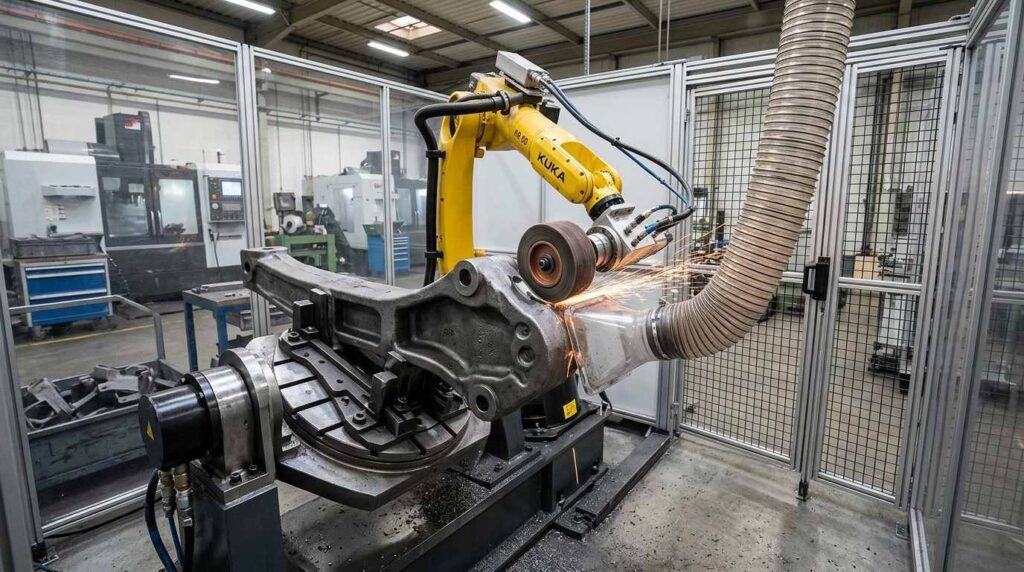
The process focuses on removing casting flash, smoothing curved contours, deburring boss edges, processing hole edges and preparing the workpiece for coating or assembly.
| 步驟 | 製程 | 目的 | 工具/系統 |
|---|---|---|---|
| 1 | 載入與定位 | Secure the cast beam accurately | 專用夾具 |
| 2 | 計劃選擇 | 選擇正確的研磨路徑 | 人機介面 / 機器人程式 |
| 3 | 外輪廓磨削 | Remove flash from curved outer edges | 研磨工具 |
| 4 | Boss Edge Deburring | Smooth raised mounting boss edges | 靈活的去毛刺工具 |
| 5 | 孔邊去毛刺 | Remove burrs around mounting holes | 小磨頭 |
| 6 | Rib and Transition Finishing | Process reinforced ribs and local transitions | Compliant abrasive tool |
| 7 | 品質檢驗 | 檢查毛刺清除情況及受保護區域 | 手動或目視檢查 |
| 8 | 卸貨與清潔 | 清除灰塵並轉移零件 | 吹氣/真空清洗 |
步驟 1:裝載與定位
The cantilever beam is placed into a dedicated fixture. Accurate positioning is important because the robot must process curved edges, raised bosses, hole areas and local transitions without affecting protected surfaces.
The fixture should support the workpiece securely while keeping all target areas accessible to the robot. For repeated production, quick positioning features can be added to improve loading efficiency and positioning consistency.
步驟 2:選擇計劃
The operator selects the correct robot program according to the cantilever beam model. If the manufacturer produces several similar structural castings, each part can have its own saved program.
For mixed production, barcode scanning, fixture recognition or recipe management can be used to reduce the risk of selecting the wrong process.
Step 3: Outer Contour Grinding
The robot first processes the curved outer contour and parting line areas. These sections often contain casting flash, raised edges or uneven local defects after casting.
An abrasive grinding tool follows the programmed contour path to remove flash and smooth the edge profile. Compared with manual grinding, the robot can maintain more stable tool movement along curved surfaces.
Step 4: Boss Edge Deburring
After the outer contour is finished, the robot processes the raised mounting bosses and pad edges. These areas are important because they are often close to assembly or positioning features.
A flexible deburring tool can remove local burrs around boss edges while reducing the risk of over-grinding mounting-related surfaces. The process path should clearly define target and protected zones.
步驟 5:孔邊去毛刺
Hole edges may contain burrs after casting, drilling or machining. If these burrs are not removed, they may affect fastener installation, handling safety or assembly quality.
The robot uses a small grinding head or deburring tool to process the hole edges with a defined circular or local path. This improves consistency and reduces manual rework.
Step 6: Rib and Transition Finishing
Reinforced ribs, curved transitions and local junctions often retain small burrs or flash after the main grinding steps. These areas are easy to miss during manual finishing.
The robot can process these local features with predefined approach angles and suitable abrasive tools. This helps improve finishing coverage across the whole workpiece.
步驟 7:品質檢查
After grinding, the cantilever beam is inspected for flash removal, edge smoothness, boss deburring quality, hole edge finishing and surface protection. Key inspection areas include the curved outer contour, raised boss edges, mounting holes, ribs and parting line zones.
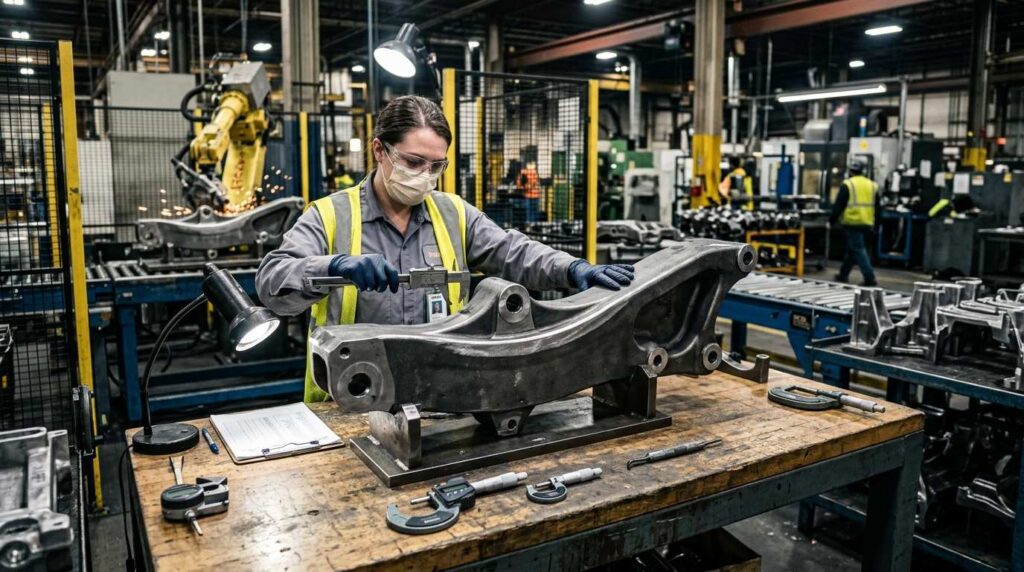
Inspection can be performed manually or with visual assistance depending on the production requirements.
步驟 8:卸載與清潔
The finished part is removed from the fixture. An air blast, brush or vacuum pass removes the last of the dust. The part can then move to coating, machining, assembly or packaging.
加工困難與解決方案
Cantilever beams are challenging because they combine curved cast contours, raised mounting bosses, hole edges and reinforced local transitions. The robotic system must provide accurate positioning, controlled tool paths and stable finishing on different feature areas.
| 挑戰 | 原因 | 機器人解決方案 |
|---|---|---|
| Curved Outer Contours | Arc-shaped edges and profile transitions require changing tool angles | 編程的輪廓磨削路徑 |
| Boss Edge Burrs | Raised mounting pads create local burr-prone areas | Flexible deburring tool for boss edges |
| Hole Edge Burrs | Holes may retain burrs after casting or machining | Small tool with defined circular path |
| 表面保護 | Mounting-related areas must not be over-ground | Accurate fixture and protected process zones |
| Casting Variation | Flash thickness may vary between batches | Compliant grinding or force control |
Difficulty 1: Curved Contours Require Stable Tool Angles
The cantilever beam has curved outer edges and local profile transitions. Manual workers need to constantly adjust the grinding angle, which can lead to inconsistent edge quality.
The solution is to use a programmed robotic contour path. The robot follows the same curve on each part and maintains more stable tool orientation, improving consistency across batches.
Difficulty 2: Raised Boss Areas Are Easy to Over-Grind
Raised mounting pads and circular boss areas are typical on this part. They may need burr removal, while their functional surfaces must stay protected.
The solution is to define clear grinding boundaries around the boss edges. A flexible deburring tool can remove local burrs while reducing the risk of damaging mounting-related surfaces.
Difficulty 3: Hole Edges Require Controlled Deburring
Hole edges and local openings may retain burrs after casting or machining. Manual deburring around holes may be inconsistent, especially in repeated production.
The solution is to use a small grinding head or deburring tool with a defined circular path. This allows the robot to process hole edges consistently without unnecessary surface removal.
Difficulty 4: Reinforced Ribs and Transitions Create Local Burrs
Rib transitions and curved junctions often retain small burrs or flash. These features are easy to miss during manual grinding.
The solution is to divide the part into feature zones and program local finishing paths for each area. This improves coverage and reduces missed burrs.
Difficulty 5: Casting Variation Requires Flexible Processing
Casting flash may vary slightly from one part to another. A rigid grinding path may not always provide stable contact.
The solution is to use compliant grinding tools or force-controlled processing. This helps the robot adapt to minor casting variation while maintaining consistent finishing quality.
Application Scenario
Scenario Background
In this scenario an automotive casting plant supplies cantilever beam components to chassis and suspension assemblies. Curved outer contours, raised bosses, hole edges and reinforced transitions all require finishing before the part reaches coating or assembly.
Manual flash and burr removal keeps pace until volumes rise; from there, curved profiles, boss edges and hole areas are the features that resist standardization most.
技術挑戰
Casting flash follows the curved contour, and burrs collect at boss edges, hole edges and rib transitions. Between operators the results differ, and the easy-to-miss spots do get missed.
Assembly-related surfaces must survive the process intact while burr removal gains consistency, and cast iron dust remains a workshop issue throughout.
解決方案
The work fits a UBRIGHT SOLUTIONS cell built on a six-axis industrial robot with a dedicated fixture, an abrasive grinding tool, a flexible deburring tool, a small grinding head and dust extraction.
Curved contour and parting lines come first; raised boss edges, mounting holes and rib transitions follow. The fixture delivers repeatable positioning, and the robot program separates target zones from protected ones.
| 項目 | 組態 |
|---|---|
| 工件 | Cast Cantilever Beam |
| 典型尺寸 | 730 × 540 × 220 mm |
| 主要製程 | 機器人研磨 |
| 輔助流程 | 去毛刺和圓邊 |
| 機器人 | 六軸工業機器人 |
| 模具 | Abrasive Grinding Tool, Flexible Deburring Tool, Small Grinding Head |
| 固定裝置 | Dedicated Cantilever Beam Fixture |
| 塵埃控制 | 帶集塵功能的密閉式機箱 |
| 應用 | Contour grinding, boss edge deburring, hole edge finishing |
Expected Results
Run in this configuration, the cell should hold finishing quality steady on curved contours, boss edges and mounting holes, while taking over the repetitive grinding work across repeated beam models.
Dust control from the enclosed cell makes the finishing step far easier to manage alongside batch production.
| 結果區域 | Expected Improvement |
|---|---|
| Contour Finishing | More consistent grinding on curved outer edges |
| Boss Edge Quality | More stable burr removal around raised pads |
| 孔邊去毛刺 | Reduced variation around mounting holes |
| 減少勞動力 | 減少重複性手動研磨的工作量 |
| 表面保護 | Better control of target and protected areas |
| 塵埃控制 | Cleaner finishing environment with extraction system |
常見問題
Q1: Why is robotic grinding suitable for cantilever beams?
Robotic grinding is suitable because cast cantilever beams have curved contours, raised bosses, hole edges and local transitions that require repeatable finishing. The robot can process these areas with stable paths and reduce variation caused by manual grinding.
Q2: What areas of a cantilever beam are typically processed?
Common processing areas include curved outer contours, parting lines, mounting boss edges, hole edges, ribs and local transition zones. The exact processing scope depends on the part structure and finishing requirements.
Q3: Can robotic grinding remove burrs around mounting bosses?
Yes. With suitable flexible deburring tools and defined robot paths, the system can remove burrs around raised bosses and mounting pads while protecting important surfaces.
Q4: Can the robot deburr hole edges on cantilever beams?
Yes. The robot can use a small grinding head or deburring tool to process hole edges with a controlled path. This helps improve consistency around mounting holes and local openings.
Q5: Does the robot process the whole cantilever beam surface?
Not always. In most cases, the robot processes defined target areas such as contours, boss edges, hole edges, parting lines and local burr-prone transitions. Protected assembly surfaces can be avoided.
Q6: Can one robotic cell process different cantilever beam models?
Yes. Different models can be processed if suitable fixtures and robot programs are prepared. For similar cast structural parts, quick-change fixtures help cut changeover, and layouts such as our 6-axis dual-station deburring equipment keep one station finishing while the other is reloaded.
Q7: Is polishing required for cantilever beams?
In most cases, no. Cantilever beams usually require grinding, deburring and surface preparation rather than decorative polishing. The focus is on removing flash, burrs and sharp edges before coating or assembly.
Q8: Can the system include dust extraction?
Yes. Dust extraction is recommended for cast iron or cast steel grinding. The robotic cell can include an enclosure, local suction and filtration equipment to improve workshop cleanliness.
總結
Cantilever beams are automotive cast structural components that require reliable finishing on curved contours, mounting bosses, hole edges and reinforced transition areas. Casting flash, burrs and sharp edges can affect coating quality, handling safety and assembly consistency if they are not removed properly.
A robotic grinding solution helps cantilever beam manufacturers improve contour finishing, boss edge deburring and hole edge consistency in batch production. With dedicated fixtures, controlled tool paths and integrated dust extraction, robotic finishing is well suited to repeated automotive casting production. For a much longer structural casting on the same finishing logic, see our axle robotic grinding solution.
If your cantilever beam production still relies on manual contour grinding, boss deburring or hole edge finishing, 聯絡我們 for a customized robotic solution. Chassis and suspension castings of this kind are grouped under 汽車與電動車; the machines that process them are in 設備.